Open to full-time roles
Electronics · Robotics · Embedded Systems

Pranjay
Dhawan

B.E. ECE student at Thapar Institute. I build hardware that moves — Martian rovers, drones, and EV monitoring systems. Champion at IRC 2026.

PCB Design Firmware · IoT Robotics SolidWorks · 3D Print Altium Designer
See My Work LinkedIn ↗
Pranjay Dhawan
scroll

01 — About

Building at the intersection of hardware & software

I recently completed my B.E. in ECE at Thapar Institute along with a Product R&D Engineering internship at Zipbolt Innovation, and I'm now a Research Associate at Thapar working on an exoskeleton. My work sits at the edges: where a mechanical constraint meets an electrical one, or where sensor data needs to travel reliably across a rover chassis on Mars-like terrain.

I specialize in the full hardware loop — schematic capture, custom PCB fabrication in Altium, embedded firmware, SolidWorks enclosures, and field validation. I also served as Overall Student Coordinator at the Mechatronics and Robotics Society through July 2026, directing 80+ students across the International Rover and Space Drone competitions.

4 conference papers. 9+ custom PCBs. 70+ 3D-printed parts. Two international podiums. Still building.

B.E. — Electronics & Communication Engineering

Thapar Institute of Engineering and Technology, Patiala

Aug 2023 – July 2026

Diploma — Electronics & Communication Engineering

Chandigarh College of Engineering and Technology

Aug 2020 – June 2023
9+
Custom PCBs Designed
4
Conference Publications
80+
Students Coordinated
70+
3D Parts Fabricated

02 — Experience

Where I've worked

Research Associate
Aug 2026 – Present
Thapar Institute of Engineering & Technology · Patiala
  • Working on the overall structure and system integration of a walking-assist exoskeleton.
  • Learning and implementing ROS 2 and Simulink in the project, where collected human data is fed into the exoskeleton to help users walk.
Product R&D Engineer
Jan 2026 – July 2026
Zipbolt Innovation Pvt Ltd · Internship · Chandigarh
  • Developed hardware architecture and PCB for ZipSure AI EV monitoring system — sensory node + gateway node for real-time battery analytics.
  • Designed and prototyped EV-compatible enclosures in SolidWorks with in-house 3D printing.
  • Enhanced firmware for ESP32-based IoT devices at EV charging stations — advanced debugging and diagnostics features.
Core Electronics Engineer
Feb 2022 – Jul 2023
The MindCrafters · Internship · Chandigarh
  • Engineered and fabricated 4 custom PCBs using EasyEDA for robotic applications.
  • Led development of 4 humanoid robot prototypes and 3 IoT systems using ThingSpeak.
  • Executed 3D printing and CAD design for 50+ complex models in SketchUp.

03 — Projects

Things I've built

Pranjay with Rover Ganga at IRC 2026 Martian Rover Ganga on terrain Team MARS with trophies — IRC & ISDC 2026
🏆 Champion — IRC 2026
Martian Rover — Ganga
Apr 2025 – Feb 2026 · International Rover Challenge

Full electronics subsystem with a simplified main PCB integrating dual Teensy 4.1 microcontrollers. Custom PDU with dual 19 V boost converters, dual bucks (5 V & 8 V), 12 V short-circuit protection, and a 5-channel solid-state relay. Led design and validation of 25+ structural components under the IRC 65 kg weight limit.

AltiumTeensy 4.1SolidWorksPrusaSlicerPower Electronics
Custom PCBs Built for This Rover — Click to Enlarge
Gen 4 Main PCB PDU PCB 12V CLP PCB SSR PCB Sensor PCB
Drone Garud — front view Drone Garud — top view Drone payload PCB — atmospheric sensor board Team MARS at ISDC 2026 award ceremony
Drone — Garud
May 2025 – Feb 2026 · 🥈 1st Runner Up ISDC 2026

Redesigned 4 structural points, cutting chassis weight from 650 g to 450 g. Full Pixhawk electronic integration — GPS/IMU, telemetry, power routing — with PID tuning and vibration isolation.

AltiumPixhawkMission PlannerSolidWorks
VocalEyes Cap Mount CAD
VocalEyes
Feb 2025 – Dec 2026 · Assistive Technology

Raspberry Pi 5 device for the visually impaired — I2S DAC + Pi Camera 3 for real-time object awareness. 3D-printed universal cap mount fits any head size.

PythonRaspberry Pi 5SolidWorksPrusaSlicer
Alaknanda rover navigating terrain at IRC 2025 Alaknanda with 1st Runner Up trophy — IRC 2025 Team at International Space Robotics Week Award Ceremony 2025 Alaknanda — close-up of electronics and drill arm Alaknanda — rover at TIET campus
Martian Rover — Alaknanda
Aug 2024 – Feb 2025 · 🥈 1st Runner Up IRC 2025

Electronics subsystem with 6 sensors, 18 motor drivers, and power management. Mentored team in 3D-printing 45+ structural components for mechanical stability.

C/C++Teensy 4.1SolidWorks

04 — Hardware

PCB Design Gallery

Gen 4 Main PCB

Gen 4 Rover — Main PCB (Arm Base Soil PCB)

Dual Teensy 4.1 · Full rover control · 18 motor drivers · Martian Rover Ganga

PDU PCB

Power Distribution Unit

Dual 19 V Boost · 5 V & 8 V Buck · Gen 4 Rover Ganga

12V CLP PCB

12 V Current Limiting Protection

Short-Circuit Protection PCB · Gen 4 Rover Ganga

SSR PCB

5-Channel Solid State Relay

Power Switching PCB · Gen 4 Rover Ganga

Soil Sensor PCB

Sensor PCB — Soil & Atmospheric

Teensy 4.1 · MICS6814 · BME280 · ACD10 · RS485 · Gen 4 Rover Ganga

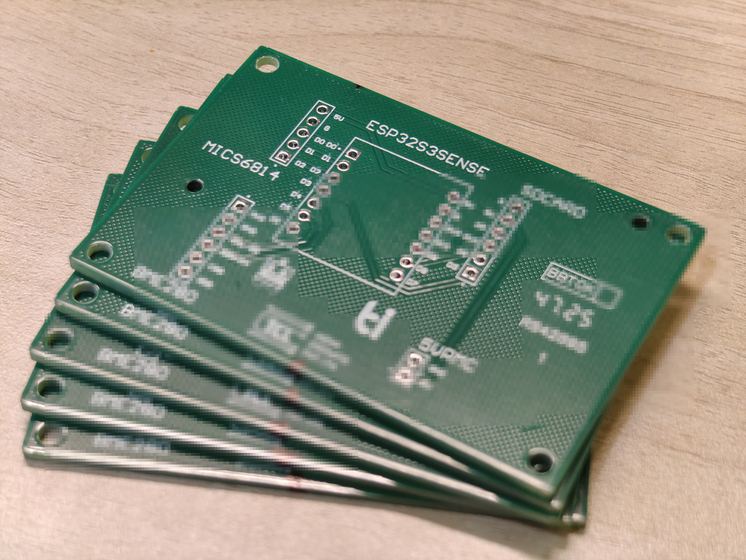
Drone Garud — Atmospheric Sensor PCB batch

Drone Garud — Atmospheric Sensor PCB

ESP32-S3-Sense · MICS6814 · BME280 · SD Card · Drone Garud payload

Mechanical Design

VocalEyes Itr 3.1

VocalEyes — Cap Mount Itr 3.1

Universal ergonomic mount for Raspberry Pi 5 assistive device · SolidWorks

VocalEyes Itr 4 Trial

VocalEyes — Cap Mount Itr 4 (Trial)

Refined prototype — improved fitment, reduced weight · SolidWorks


05 — Research

Publications & Conferences

IROS
2026
International Conference on Intelligent Robots and Systems (IEEE IROS, 2026) — ROSE Workshop

“Alaknanda: A ROS 2-Enabled Modular Mars Rover for Field and Astrobiological Exploration” — a modular, ROS 2-enabled rover platform for challenging, unstructured environments, accepted for poster presentation at the Robotic One-Shot Exploration from Deep Ocean to Deep Space (IEEE IROS, 2026 - ROSE) Workshop in Pittsburgh, USA. My contribution: electrical architecture design and implementation, along with power system design and validation.

Under mentorship of Dr. Ashish Singla & Dr. Sachin Kansal · Accepted Sep 2026
ICSCPS
2026
International Conference on Smart Cyber Physical Systems

Designed the system architecture of an ESP32-based outdoor multi-sensor tracker — integrating GNSS, thermal and RGB sensing, power management, and IoT data transmission into a unified embedded platform.

Under guidance of Dr. Amanpreet Kaur · Accepted Jan 2026
AIR
2025
7th International Conference of The Robotics Society (AIR)

Research on 4 custom PCB designs, thermal management, and battery modeling for a multi-subsystem Martian rover, presented at a leading international robotics conference.

Under mentorship of Dr. Ashish Singla & Dr. Sachin Kansal · Jun 2025
IFToMM
2025
3rd IFToMM for SDG Conference — Extended Abstract

Custom Martian-rover power system achieving 18 Nm torque and 86.7% power efficiency while reducing heat-induced losses through optimised thermal design.

Under guidance of Dr. Ashish Singla & Dr. Sachin Kansal · Jun 2025

06 — Skills

Tools & Technologies

PCB & EDA
Altium DesignerEasyEDAKiCadXilinx VivadoAutoDesk EagleMentor Graphics
Mechanical & 3D
SolidWorksPrusaSlicerSketchUp3D Designing & Printing
Firmware & Code
C / C++PythonHTMLArduino IDESTM32Cube IDE
Platforms
ESP32Teensy 4.1Raspberry Pi 5PixhawkArduPilot
Core Domains
Schematic CapturePCB DesignPower ElectronicsAnalog ElectronicsDigital System DesignComputer ArchitectureMicrocontrollersEmbedded HardwareRoboticsIoT Systems
Dev Tools
Mission PlannerThingSpeakBlynkMATLABVS CodeGitHubVercelThermal Management

07 — Honors

Awards & Recognition

🏆
Champion — International Rover Competition
2026
🥈
1st Runner Up — Space Drone Competition
2026
🥈
1st Runner Up — International Rover Competition
2025
🎓
₹1 Lakh Academic Scholarship — Thapar Institute
Merit Award

Get in touch

Send me a message

I'll reply from pdhawan50_be23@thapar.edu

Or write directly at pdhawan50_be23@thapar.edu

✅

Message sent!

Thanks for reaching out. I'll get back to you at
as soon as possible.